Research
Soft Robotics
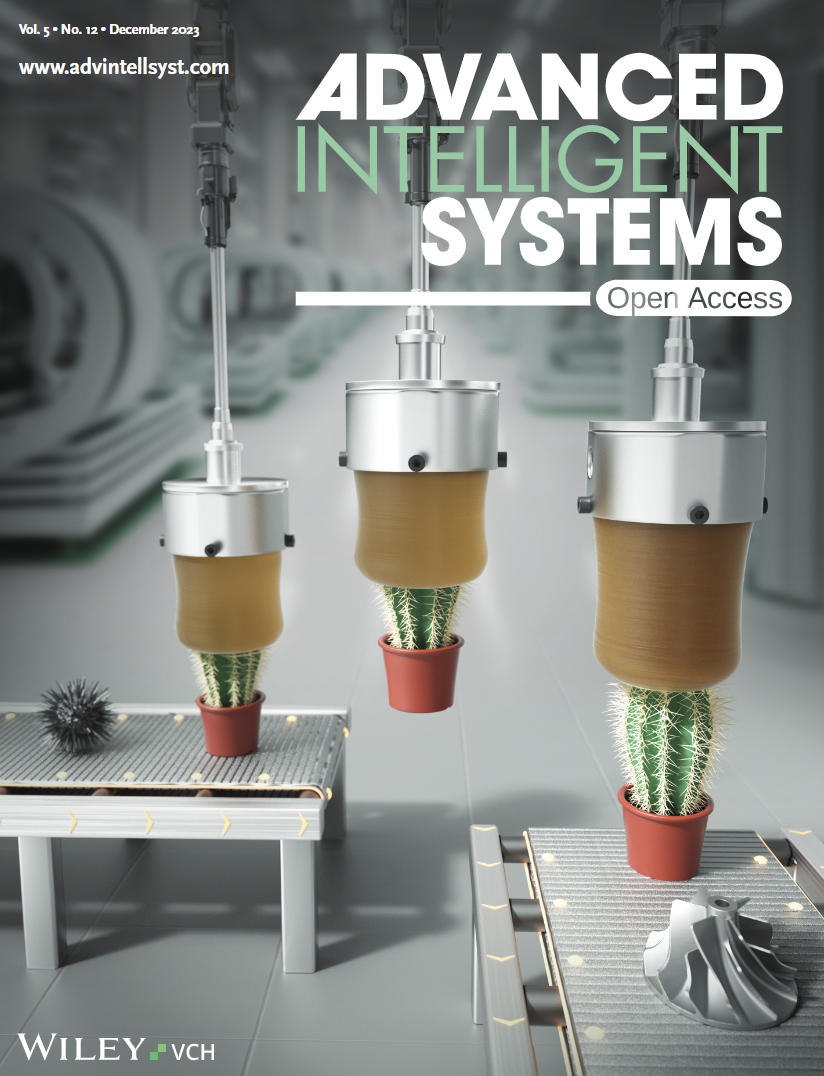
I design compliant, form-adaptive, and resilient robot bodies that use morphology and material intelligence to simplify physical interaction. This work spans hybrid suction-jamming grippers, self-healing soft grippers, variable-stiffness fingers, and integrated sensing, with an emphasis on reliable operation in uncertain and industrial environments.
Keywords: soft grippers, self-healing materials, variable stiffness, embodied intelligence, soft sensing
Selected papers
Dexterous Manipulation
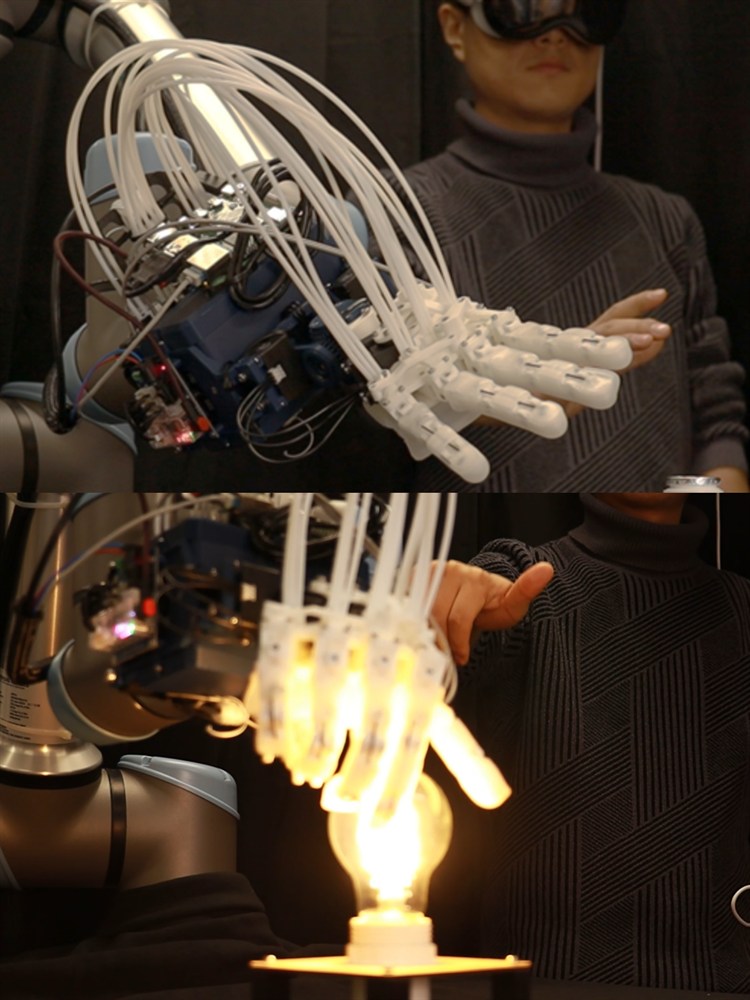
I develop dexterous hands and arm-hand systems that manage high-dimensional motion through mechanical coordination, task-oriented morphology, and embodied dimensionality reduction. Piano playing, hand-object interaction, and teleoperation provide demanding testbeds for studying anthropomorphic design, passive dynamics, contact-aware control, and real-time multi-joint coordination.
Keywords: dexterous hands, arm-hand coordination, anthropomorphic design, teleoperation, contact-rich manipulation
Selected papers
Bio-Inspired Robot Design and Control
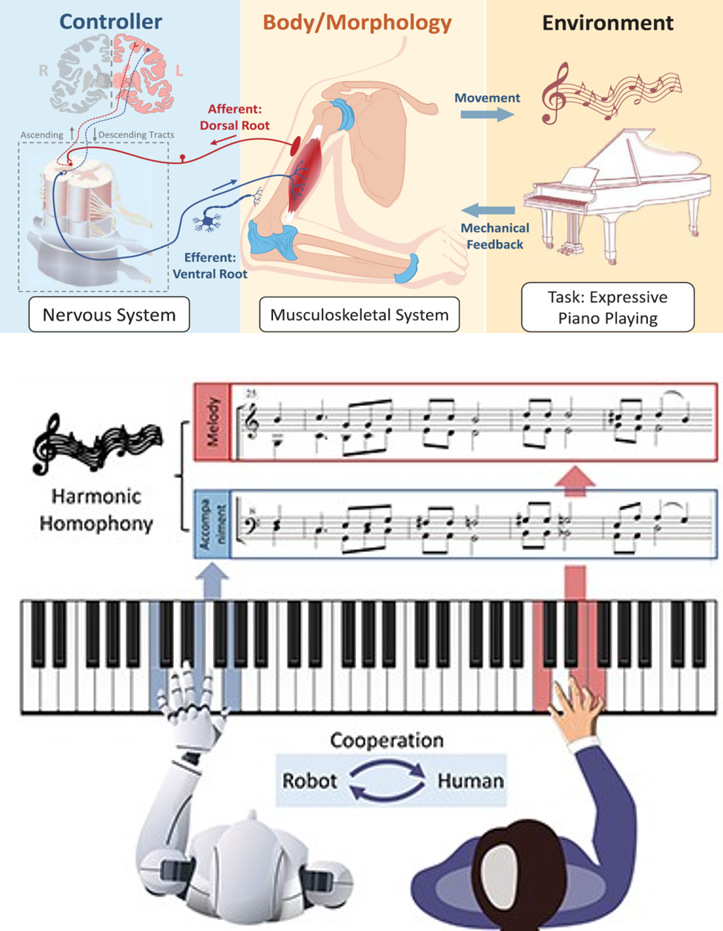
I draw inspiration from nervous, musculoskeletal, and behavioral systems to co-design robot morphology and control. This direction combines neural rhythm generation, embodied dynamics, adaptive locomotion, and human-robot co-adaptation, seeking efficient behavior that emerges from the interaction among controller, body, environment, and human partners.
Keywords: bio-inspired robotics, embodied control, neural rhythms, adaptive locomotion, human-robot co-adaptation
Selected papers
Academic Services
| Role | Event Name | Time/Venue |
|---|---|---|
| Program Chair | The 6th International Conference on Embodied Intelligence | Online, 2026 |
| Associate Chair | The 24th Towards Autonomous Robotic Systems Conference (TAROS) | Cambridge, 2023 |
| Guest Editor | Biomimetics Special Issue: Biomimetic Humanoid Robotics: From Foundation Models to Whole-Body Control Co-guest editor with Prof. Junzhi Yu | Biomimetics (SCIE, JCR Q1), 2026-2027 |
| Review Editor | Front. Robot. AI, Soft Robotics Section | 2023 |
| Special Issue Guest Editor | Front. Robot. AI Special Issues | 2024, 2025 |
| Reviewer | T-RO; T-ASE; MMT; SORO; RA-L; AISY; ARR; EAAI; SciRep; ICRA; IROS; RoboSoft; ASR; Front. Robot. AI; Sensors | Selected journals and conferences |
Mentoring Experience
| Year | Mentee | Project / Institution |
|---|---|---|
| 2026 | Baptiste Ferrer | Semester Project, EPFL |
| 2026 | Victor Van den Heuvel | Master Project, École Polytechnique Fédérale de Lausanne |
| 2025 | Yu (Antares) Zhang | PhD, École Polytechnique Fédérale de Lausanne |
| 2024 | Mingqi Yuan | PhD student, The Hong Kong Polytechnic University |
| 2023 | Lawrence Schofield | Master Thesis, University of Cambridge |
| 2022 | Emily Zhang | Undergraduate, University of Cambridge |
Teaching Assistant
| Term | Course | Details |
|---|---|---|
| 2022 Fall | Integrated Design Project, University of Cambridge, Part IB | Undergraduate course; Instructor: Dr. Gemma Bale |
| 2021 Fall | 4M20: Introduction to Robotics, University of Cambridge, Tripos Part IIB | Undergraduate and postgraduate course; Instructors: Prof. Fumiya Iida and Prof. Amanda Prorok |